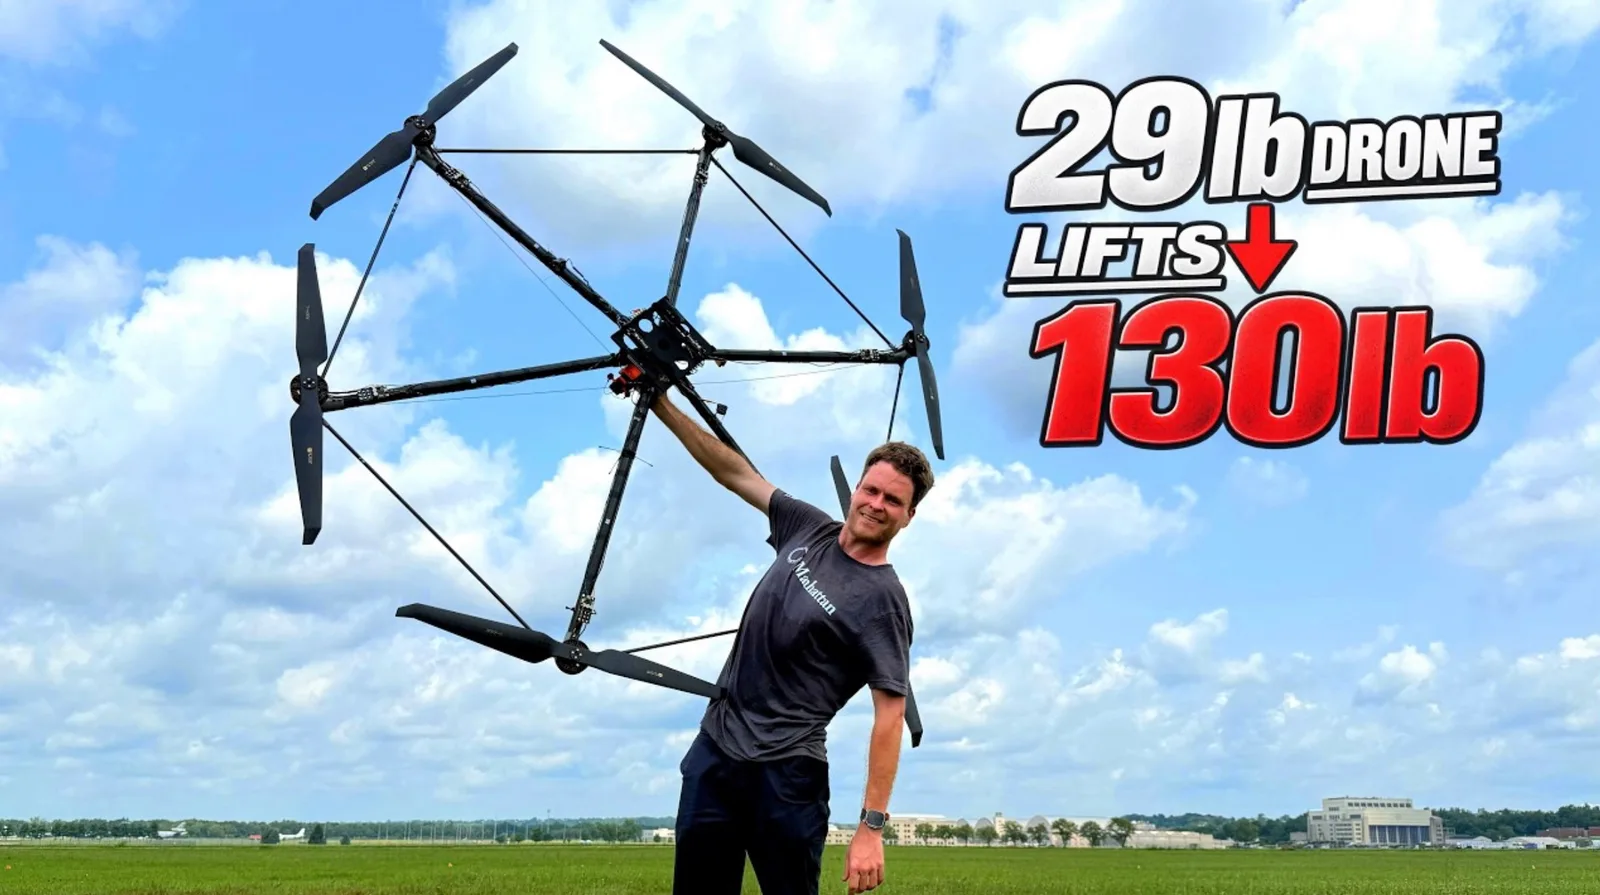
MTech Operations took second at the DARPA Lift Challenge with a 3.64:1 payload-to-weight ratio and a $750,000 check, and the run that would have beaten it died three quarters of the way around the Dayton course when a single motor got too hot to hold its magnets. That failure now has telemetry attached to it. Luke Maximo Bell, the South African builder who put the hexacopter together with his father Mike and flew it for MTech, has published the team’s build log and flight data from the week.
It changes the conclusion DroneXL drew in August. After the awards, this site described the gap between the winning 3.84:1 run and DARPA’s 4:1 target as a wall made of watt-hours, because at least one aircraft went quiet three nautical miles into a five-nautical-mile course on drained packs. MTech’s account puts a different failure at the front of the queue. Bell’s mid-course math had the pack at roughly 60% with half the run to go, which he read as enough to finish. The motors are what ran out of margin.
Motor Five Demagnetized Three Quarters Of The Way Around The Course
Bell’s account puts the failure at motor five. The downwind motors ran hotter than the upwind ones on the loaded leg, and that motor eventually got hot enough for its magnets to start demagnetizing. The aircraft lost altitude, dropped below the 100-foot (30-meter) floor, and the run stopped counting.
Two problems had already eaten into the attempt. The GPS unit came off the airframe on the team’s first launch of the final window, forcing a landing, and with no spare packs the drone went back up on batteries charged to 80%. Then it failed to climb on schedule because an altitude parameter had been left in feet rather than meters. An engineer from MTech Operations, which Bell describes as a Massachusetts outfit that joined the effort, caught it mid-flight and pushed the correction, and the aircraft cleared the floor at 0.48 nautical miles against a 0.5 limit.
In the account he published, Bell notices the aircraft wobbling at 2.8 nautical miles and reads it as a tuning artifact rather than a heat problem, on the assumption that the motors would be fine at 248°F (120°C). What the team had not accounted for was the temperature split between upwind and downwind motors on a course flown in one direction, which is the kind of asymmetry that only shows up on a full-payload run in Ohio in August.
The Hexacopter Was Built For Thrust Headroom Rather Than Efficiency
Bell’s team picked a hexacopter because the scoreboard measured payload over weight and nothing else. More propellers meant more thrust headroom for a course flown at speed, and the finished aircraft weighed 29 pounds (13 kilograms) against the 55-pound (24.9 kilogram) cap DARPA set for every entry.
Choosing the propulsion took a purpose-built test rig. Bell mounted a strain gauge rated to 330 pounds (150 kilograms) under a wooden frame, wired an RPM sensor and a thermistor salvaged from a 3D printer hot end into the motor, and logged thrust, throttle, motor coil temperature and ESC temperature across two weeks of testing in his father’s yard. The winning combination was a T-Motor MN8017 turning a G30 propeller, swapped late in the program for T-Motor’s HPL propellers, four inches longer and more efficient. Hover power dropped from about 8.1 kW to 6.9 kW on that change alone.
Mike Bell designed the frame as a carbon fiber truss rather than the stacked-arm layout his son used for the endurance drone that flew 3 hours 31 minutes on one charge in February. Flight control ran on a CubePilot Cube Orange+ with ArduPilot. Power came from Amprius SA504 silicon-anode pouch cells, which Bell rates at 390 Wh/kg and a 6C discharge, hand-welded into four parallel packs so the aircraft could still land if one failed. Loaded runs came out most efficient at around 35 mph (56 km/h).
A Disallowed Landing And A Snapped Arm Preceded The 3.64 Score
MTech’s first qualifying score, a 3.41:1 run, was thrown out after the aircraft landed outside the required 10-foot circle and rival teams complained. The team reflew at 3.64:1 the same weekend, and that is the number DARPA certified for second place and $750,000.
The weeks before that went worse. At home the team lost one aircraft to a 3D-printed wing that detached in autonomous flight and dropped the drone in water, and another to a power plug that vibrated loose in flight. More than 140 tuning flights went in before anyone boarded a plane, and Bell says he still was not happy with the tune. Then during the first 4:1 attempt in Dayton, a motor mount snapped at 1.3 nautical miles and destroyed the aircraft. Mike Bell’s CFD work in Flow360 had already flagged the middle motors as the most stressed on the frame, so the break landed where the simulation said it would.
They rebuilt overnight and switched to 3D-printed aluminum motor mounts from PCBWay, chosen partly to pull heat out of the motors. “If you’re not breaking them, you’re not pushing them hard enough,” Bell says of the wreckage. Ground testing showed the mounts absorbing heat as intended. Over four loaded nautical miles, they bought time without solving the problem.
Two commercial relationships belong on the record here: Onshape sponsored Bell’s video and is the CAD package the airframe was designed in, and PCBWay supplied the aluminum mounts.
The 2028 Rules Push Straight Into The Thermal Limit
DARPA raised the bar for 2028. The minimum qualifying payload doubles from 110 pounds (49.9 kilograms) to 220 pounds (99.8 kilograms), the course doubles from 5 nautical miles to 10, and the 55-pound aircraft cap stays where it is. Every 2028 qualifying run therefore starts at 4:1.
The course change is the harder one. Loaded distance goes from 4 nautical miles to 8, which roughly doubles the time a motor spends at full load before it gets any relief. MTech’s motors reached the demagnetization point somewhere inside the first four. DroneXL’s report on the 2028 rules framed the new numbers as turning the old target into the entry fee, and Bell’s data suggests the aircraft that clears it will be the one with a cooling answer rather than a lift answer.
DroneXL’s Take
I wrote in August that between 3.84 and 4:1 sits a wall made of watt-hours, and Bell’s logs are the most detailed look inside that wall anyone has published. My read is that I named the wrong material. For MTech the wall was made of degrees, not watt-hours: the pack was still tracking to finish when motor five let go, and the aircraft came down because a magnet reached its limit on the downwind leg.
The concession is real. Energy did end runs in Dayton. DARPA’s program manager counted four attempts configured above 4:1 that nobody finished, one of them going quiet three miles in on drained packs. But both failure modes are the same variable seen from two sides. Time under full load drains the pack and heats the coils at once, and 2028 doubles that time while the weight cap stays fixed. Whoever wins in two years will have spent weight budget on thermal mass and airflow rather than another 10% of thrust.
DARPA’s published results give ratios and prize money, not failure modes, which is why a father-and-son build video is currently the most detailed public account of why the 4:1 barrier held. Sixty-plus teams flew in Dayton and the engineering from the attempts that failed sits in private logs.
The week established something else Washington keeps missing. A South African father and son, flying under a Massachusetts company, crashed through an entire build season and still left a U.S. defense competition with $750,000 and the second-best certified ratio in the field. That is what an open call produces. DroneXL has spent this year covering the alternative, where American capability gets pursued by banning hardware instead of paying for performance, and the half-prize clause we flagged before the first weigh-in marks the difference: DARPA wrote down what it would pay for and paid exactly that. Nobody had to be protected from anything.
Bell has been in DroneXL’s pages all year, from the endurance builds to the Guinness record for longest small electric multirotor flight in July. Watch the 2028 entry list for whether MTech returns with a cooling-first airframe. If the team that got closest comes back having redesigned around heat, the constraint is understood. If the field shows up with more thrust again, Dayton repeats itself over twice the distance.
Sources: Luke Maximo Bell on YouTube, DARPA Lift Challenge results, DARPA, DroneXL’s DARPA Lift Challenge results coverage
DroneXL uses automated tools to support research and source retrieval. All reporting and editorial perspectives are by Haye Kesteloo. Read our editorial standards.


